Allen Emmanuel Binny
PhD Student · Johns Hopkins UniversityI am a first-year PhD student at Johns Hopkins University, advised by Prof. Chinmay Maheshwari. I am interested in how autonomous systems interact with each other and with humans. The question that keeps me curious is simple: how should a robot make decisions when everyone around it has plans of their own? My earlier research focused on robot control with safety guarantees. I now want to understand how we can achieve safety and reliability through a more theoretical and algorithmic approach to multi-agent systems.
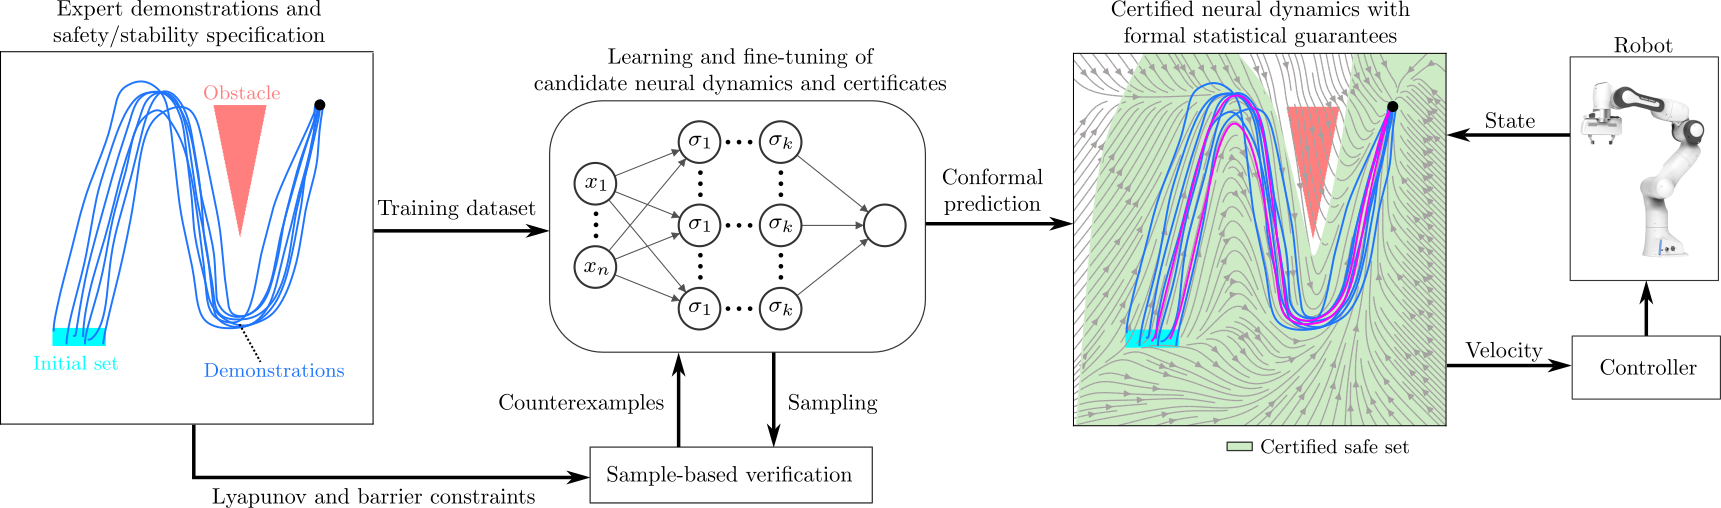
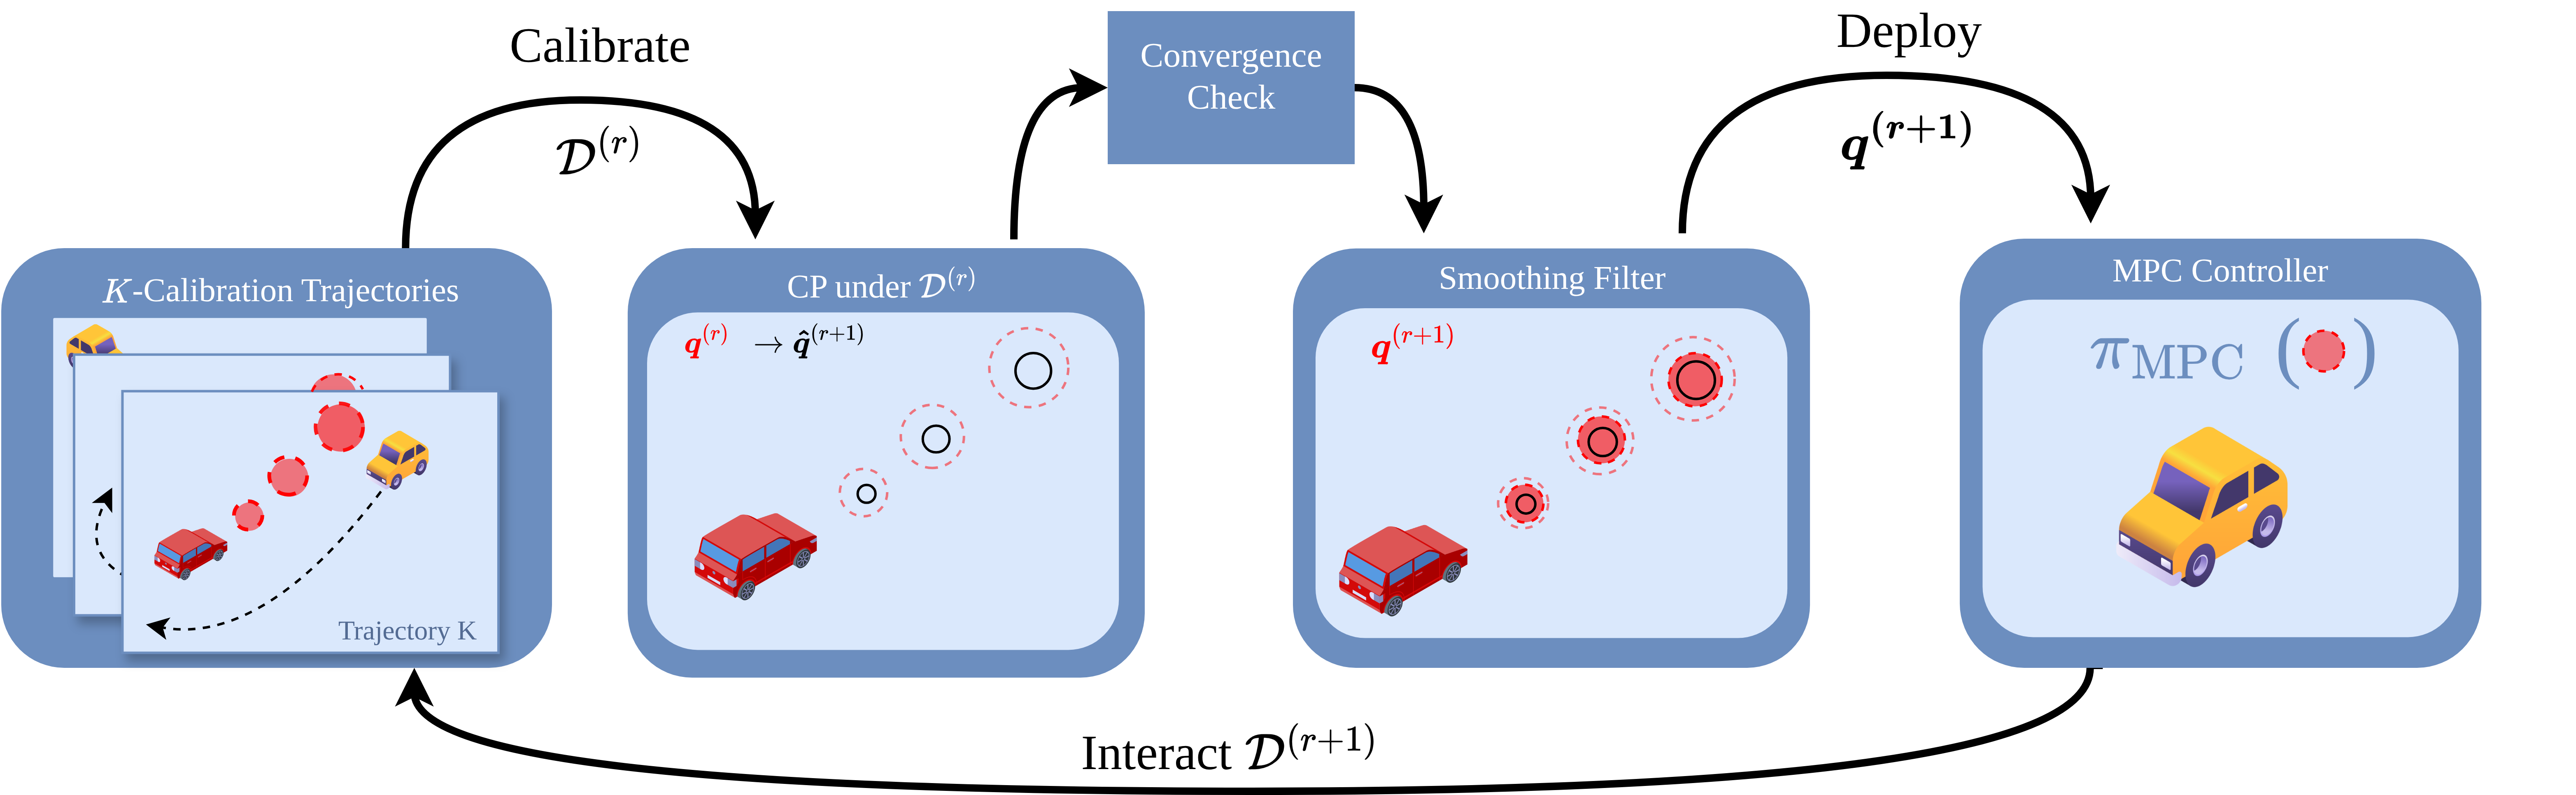
I completed my B.Tech and M.Tech at the Indian Institute of Technology (IIT) Kharagpur in 2026. Along the way, I was fortunate to learn from researchers who helped shape these interests. I worked with Prof. Anushri Dixit at the PRACTICE Lab at UCLA on conformal prediction for reactive multi-agent robot systems, and with Prof. Abdalla Swikir at the Munich Institute of Robotics and Machine Intelligence at the Technical University of Munich (TUM) on learning from demonstrations with safety and stability guarantees. I also had the good fortune to be guided by Prof. Ashish R. Hota at IIT Kharagpur and Prof. Pushpak Jagtap at the FOCAS Lab at IISc Bangalore. Together, these experiences have kept me interested in a recurring challenge: turning elegant mathematical ideas into robots we can trust outside the lab.
Outside of research, I’m always up for board games, theatre, or a good sitcom. I was also actively involved in the Debating Society at IIT Kharagpur, so a lively discussion is always welcome!
Feel free to drop me an email! (“Hello, fellow human” is a perfectly acceptable subject line)

Publications |
Competitions |

Academic Service |
